NEO's Hands: An API to the Physical World
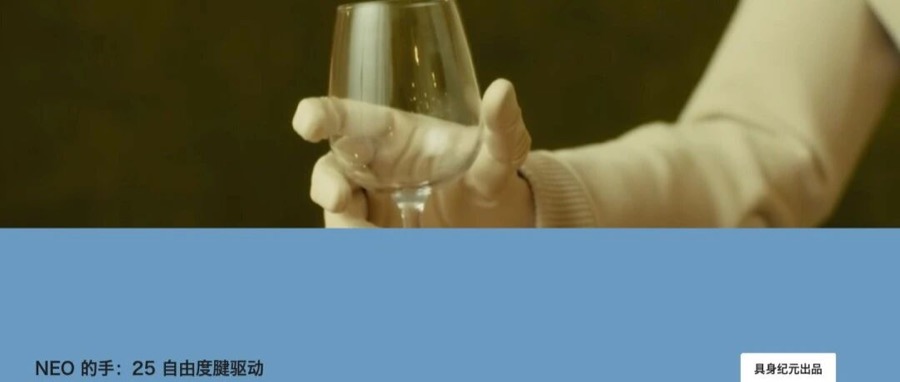
On July 9, 2026, 1X released the new generation of hands for the NEO humanoid robot: 25 degrees of freedom, tendon-driven, with dexterity, strength, safety, and reliability approaching those of human hands.
The hardware ceiling on robot capability should no longer be stuck at the "hand"; if the hand's degrees of freedom, force control, tactile sensing, durability, and mass-production capability are all in place, the real bottleneck will then shift to data and learning.
1X has introduced a breakthrough 25-degree-of-freedom (DOF) tendon-driven robotic hand for the NEO humanoid robot platform, achieving near-human levels of dexterity, strength, safety, and reliability.
1X says hundreds of hands have already come off the line, and that it has the capacity to produce 10,000 hands this year.
We are excited to announce a breakthrough for the NEO humanoid robot platform: 25-degree-of-freedom, tendon-driven hands. In dexterity, strength, safety, and reliability, they are already close to human levels.